We Vibe Coded a Full YOLOv8 App to an NVIDIA Jetson with Claude Code - No Human Code Written
Wendy Labs · Wendy Labs Team · January 30, 2026
Join our Discord community to connect with other developers building with WendyOS!
We are witnessing the absolute democratization of physical AI.
For decades, building applications for drones, smart cameras, and robots was the domain of specialized engineers with deep knowledge of embedded systems, cross-compilation toolchains, and hardware architectures. It was hard. It was slow. It was exclusive.
Today, that changes. You can now build applications for physical hardware just by asking in English.
We tried it. And it worked.
The Experiment
We gave Claude Code a simple prompt: build a real-time object detection application that runs on an NVIDIA Jetson Orin Nano with a Logitech USB webcam. The app should use YOLOv8, stream video with detection overlays, and have a nice frontend.
The catch? We didn't write a single line of code ourselves.
The only thing we did was point Claude Code to the Wendy CLI documentation using the --experimental-dump-help flag. With that context, Claude Code understood exactly how to build, configure, and deploy to WendyOS.
What Claude Code Built
In one shot, Claude Code generated:
A FastAPI Backend (server/app.py)
Webcam capture using OpenCV
YOLOv8 inference on every frame
MJPEG streaming with bounding box overlays
Detection logging with confidence scores and timestamps
Server-Sent Events for real-time updates
A React + Tailwind Frontend
Full-screen video display
Semi-transparent detection log overlay
Auto-scrolling detection feed
Clean, responsive design
A Multi-Stage Dockerfile
Node.js stage for building the React frontend
Ultralytics Jetson-optimized base image with CUDA support
Pre-downloaded YOLOv8 model for offline operation
A wendy.json Configuration
GPU entitlements for CUDA acceleration
Video entitlements for webcam access
Network host mode for direct port binding
Persistent storage for model caching
The complete application - frontend, backend, Docker configuration, and device entitlements - was generated without human intervention.
The Future: Real-Time Logic without Compilation
This experiment hints at something even more profound than just "easier coding." We are approaching a future where the loop of Write Code -> Compile -> Deploy -> Restart will become obsolete.
Imagine standing in a field with a drone. You shouldn't have to pull out a laptop, write a Python script, compile a container, and push an update just to change its mission.
You should be able to say, "Look for red jackets instead of blue cars," or "If you see a fire, fly 20 feet lower and get a thermal reading."
With the architecture we're building at Wendy Labs, it is only a matter of time before the "application" on the robot is just a container for a reasoning agent. The "logic" won't be hardcoded binaries; it will be fluid instructions processed in real-time. The robot will update its behavior instantly, without ever needing a deployment cycle.
WendyOS is the foundation for this reality. By abstracting the hardware into a clean, standard interface, we are preparing for the day when language is the operating system.
Why This Matters Today
Even right now, before we reach that sci-fi future, the impact is massive.
Traditional approach:
Learn the Jetson SDK and JetPack
Figure out CUDA, OpenCV, and PyTorch for ARM
Write the backend code
Write the frontend code
Write the Dockerfile
Debug cross-compilation issues
SSH into the device and configure it
Deploy and pray
With WendyOS + Claude Code:
Describe what you want in English.
Run wendy run.
The friction isn't just reduced - it's obliterated.
When you give AI coding agents simple, well-documented tools like the Wendy CLI, they can go from idea to deployed hardware in minutes. No human code required.
The Deployment
After Claude Code finished generating the code, deploying was a single command:
wendy run
The Wendy CLI:
Built the Docker image (cross-compiling for ARM64)
Pushed it to the Jetson's local registry
Started the container with GPU and webcam access
Streamed logs back to the terminal
Within minutes, we had a working object detection app running on the Jetson, accessible from any browser on the network.
Try It Yourself
Want to run this exact application?
Clone the sample: git clone https://github.com/wendylabsinc/samples.git
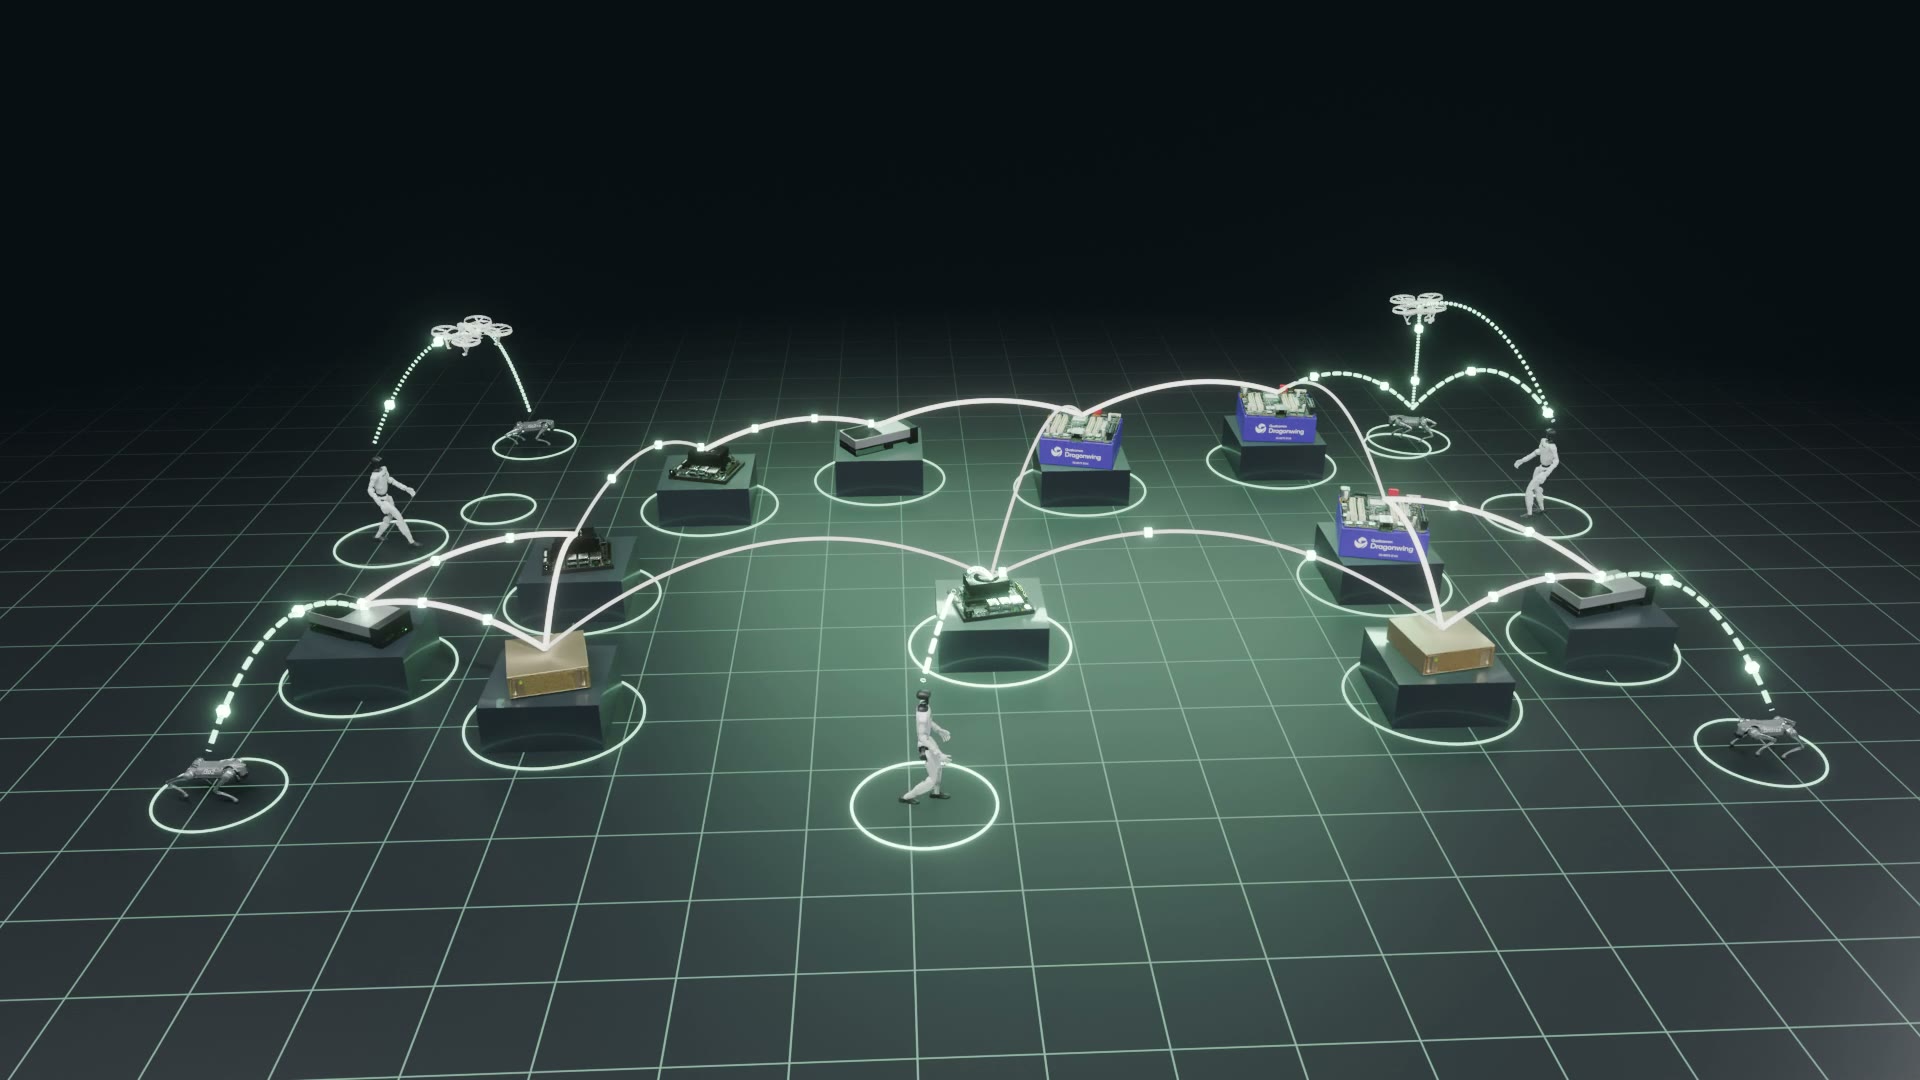
Wendy Net is a private, zero trust network built into WendyOS. Devices connect over Ethernet, Wi-Fi, Wi-Fi Aware, Bluetooth Low Energy and Wendy Cloud, and your apps find each other with ordinary mDNS and talk over plain HTTP, TCP and UDP.
Build one small Python app that lets a Qualcomm Dragonwing IQ9, a Raspberry Pi 5 and an NVIDIA Jetson find each other, encrypt their messages and hold them when a board goes dark, all without an internet connection.
Wendy Labs · Wendy Labs Team
Get started
Start with one device. Close the loop around it.
Use WendyOS on your hardware or add Wendy Agent to an existing Linux or Apple Silicon Mac. Connect sensors, run your code, and carry what you learn into the next release.