Community Spotlight: An Autonomous Go2 Inspector Built on WendyOS in 48 Hours
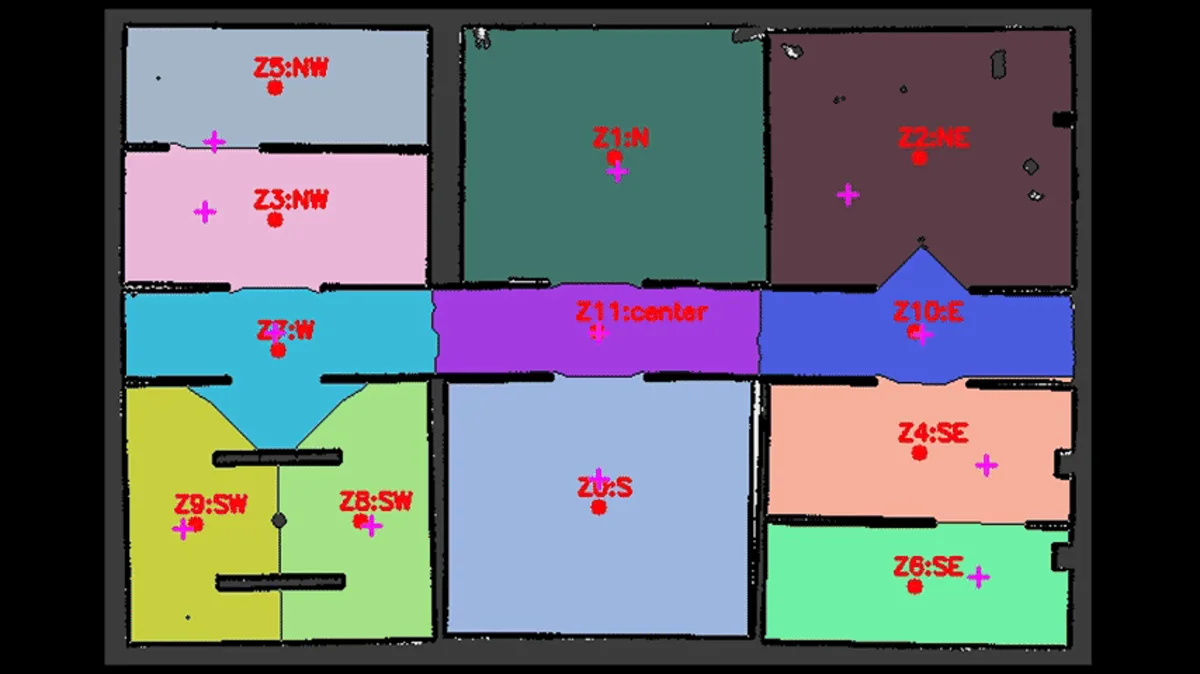
This is a community project - built by Anirudh Jupudi, Adyansh Gupta, and Manas Reddy Arumalla, and shared here with their permission. The full codebase is open source: github.com/PrestoChangoTa-da/go2-inspection.
Forty-eight hours is not a lot of time to make a robot dog autonomously map a building, split it into rooms, walk each one, read analog gauges, and file an inspection report - all steerable in plain English.
That's what a three-person team built at the EUROPE EMBODIED Robotics Hackathon (June 24 to 26, 2026), hosted by RoboTUM, START Munich, and the European Student Robotics Association. And instead of stopping at simulation, they deployed the entire pipeline on a physical NVIDIA Jetson Orin Nano booted with WendyOS, riding on a Unitree Go2 quadruped.
We didn't build this. They did. That's exactly why we're writing about it.
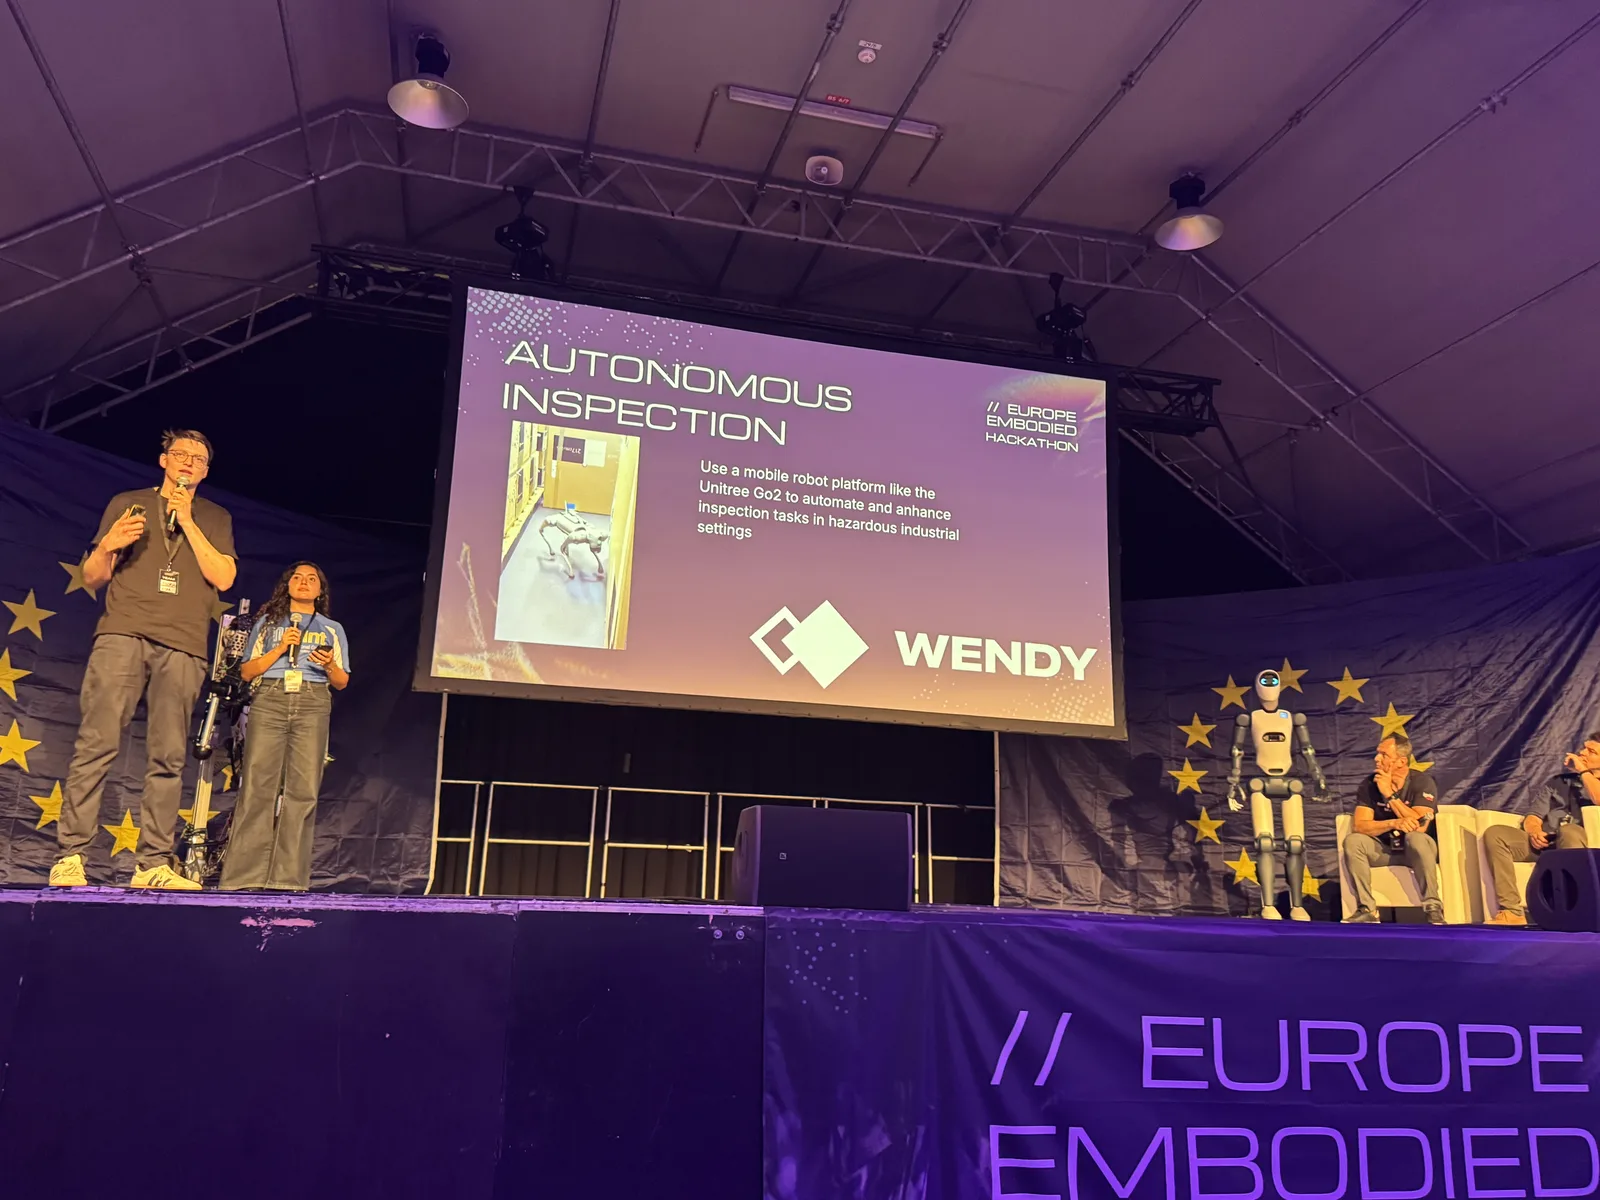
The team took on our Autonomous Inspection challenge: use a mobile robot platform like the Unitree Go2 to automate inspection tasks in hazardous industrial settings.
What they built
The team - Anirudh Jupudi, Adyansh Gupta, and Manas Reddy Arumalla - built a full autonomous facility inspection stack:
Navigation and gait. RTAB-Map LiDAR SLAM for mapping, Nav2 for navigation, and the CHAMP gait controller for quadruped locomotion, all running under ROS 2 Jazzy/Kilted. The robot explores unknown space on its own using frontier exploration - no waypoints given - then segments the finished map into labeled zones, room by room.
Vision. YOLOE runs real-time, open-vocabulary segmentation of analog gauges - voltmeters, ammeters - and fault conditions in an industrial setting. Segmented crops are sent to a Claude MCP server, which extracts precise readings and danger alerts using LLM vision.
Natural-language control. A FastMCP server bridges the LLM to ROS 2 services, exposing the whole mission as tools. The operator says "start exploring and map the area" and the LLM calls start_exploration. "Inspect zone 1 and give me the report" chains inspect_zone - navigation plus a 360-degree vision sweep - with get_report to return the structured YOLO findings and gauge telemetry. The robot was controllable both locally over Wi-Fi and globally through the cloud.
Where WendyOS fits
Everything above ran on a Jetson Orin Nano booted with WendyOS, mounted on the Go2.
This is the deployment story WendyOS exists for: a hackathon team with 48 hours and no time to fight a board. The Jetson boots into a working OS with the container runtime, GPU access, and networking already in place - so the team's hours went into SLAM tuning and MCP tools instead of flashing, drivers, and SSH archaeology. Connecting the Jetson to the cloud gave them remote control of the robot from anywhere, not just the venue Wi-Fi.
It's also a nice proof of ecosystem compatibility: ROS 2, Gazebo-trained workflows, Nav2, RTAB-Map, and CHAMP all ran as-is. If your research stack speaks ROS 2, it runs on WendyOS.
The result
In the team's own words: "48 hours of continuous, sleep-deprived coding successfully turned into an edge-deployed, cloud-connected autonomous inspector."
Explore the project:
- Codebase: github.com/PrestoChangoTa-da/go2-inspection - simulation-first, so you can run the full mission in Gazebo without owning a Go2
- Original write-up: Anirudh's post on LinkedIn
Congratulations to Anirudh, Adyansh, and Manas - and thanks to the hackathon organizers for an incredible event. (Our CTO Joannis Orlandos was on site for some late-night debugging with the team, which is our favorite kind of customer support.)
Building something on WendyOS? We'd love to feature it. Share your project in our Discord community or tag us on LinkedIn.
Related post
Expand your knowledge with these hand-picked posts.
SensorLink: Pair a Device. Borrow Its Senses.
Give your Wendy host the eyes and ears of another device. SensorLink brings cameras, microphones, and a shared model for time-series sensors into a familiar pairing workflow.
Wendy Labs - Wendy Labs Team
Free NVIDIA DGX Spark 3D model
Download our free NVIDIA DGX Spark 3D model as a GLB or an editable Blender scene with studio lighting, materials, and cameras. No signup required.
Wendy Labs - Wendy Labs Team
Start with one device. Close the loop around it.
Use WendyOS on your hardware or add Wendy Agent to an existing Linux or Apple Silicon Mac. Connect sensors, run your code, and carry what you learn into the next release.